ABOUT EMSAIL

Building Intelligence for the Physical World

EmSAIL (Embodied Spatial AI Lab) is a research laboratory at the Hong Kong University of Science and Technology (Guangzhou), dedicated to advancing spatial intelligence and embodied AI.

Our long-term vision is to build robots that continuously perceive their surroundings, understand tasks, develop persistent spatial memories, predict future changes, and act autonomously in complex real-world environments.

We bridge intelligent algorithms and physical robotic systems, pursuing an integrated approach from robot hardware and spatial perception to memory, reasoning, and action.

Perceive Understand the physical world
Remember & Reason Build memory and predict the future
Act Learn and execute real-world skills
Research

Research Directions

Spatial Intelligence

Advancing 3D/4D spatial perception, dynamic scene understanding, and persistent spatial memory for robots operating in complex, evolving environments.

Foundation Models

Developing embodied world models, vision-language-action models, and spatial reasoning to connect multimodal understanding, future prediction, and intelligent decision-making.

Robot Learning & Systems

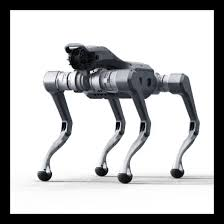
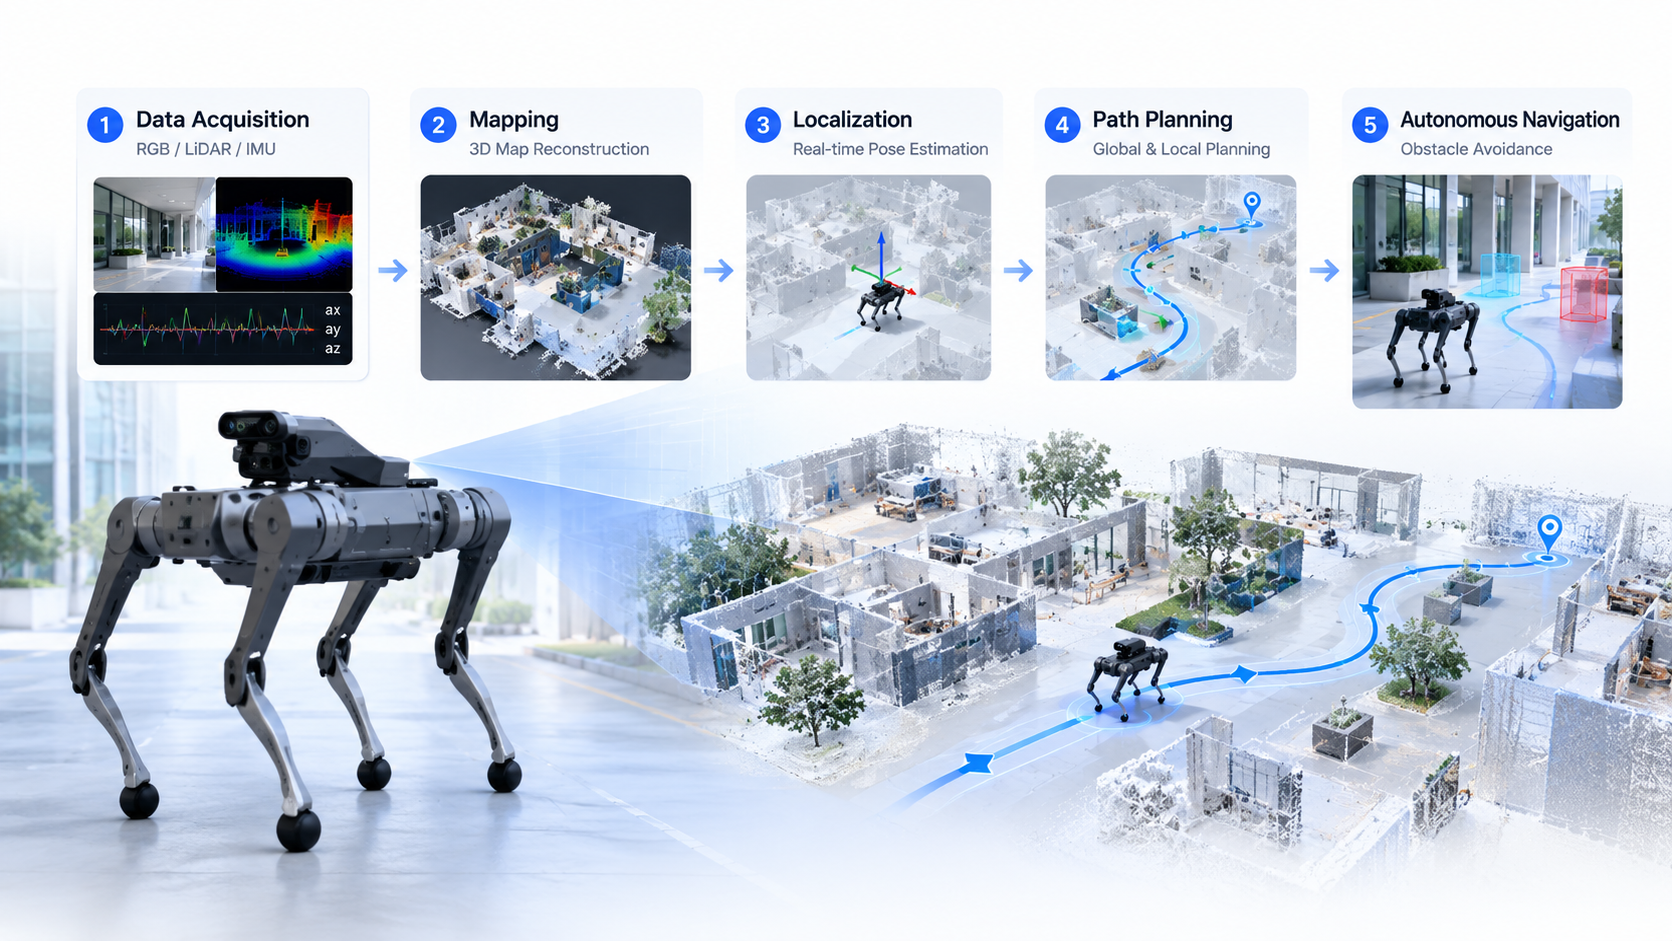
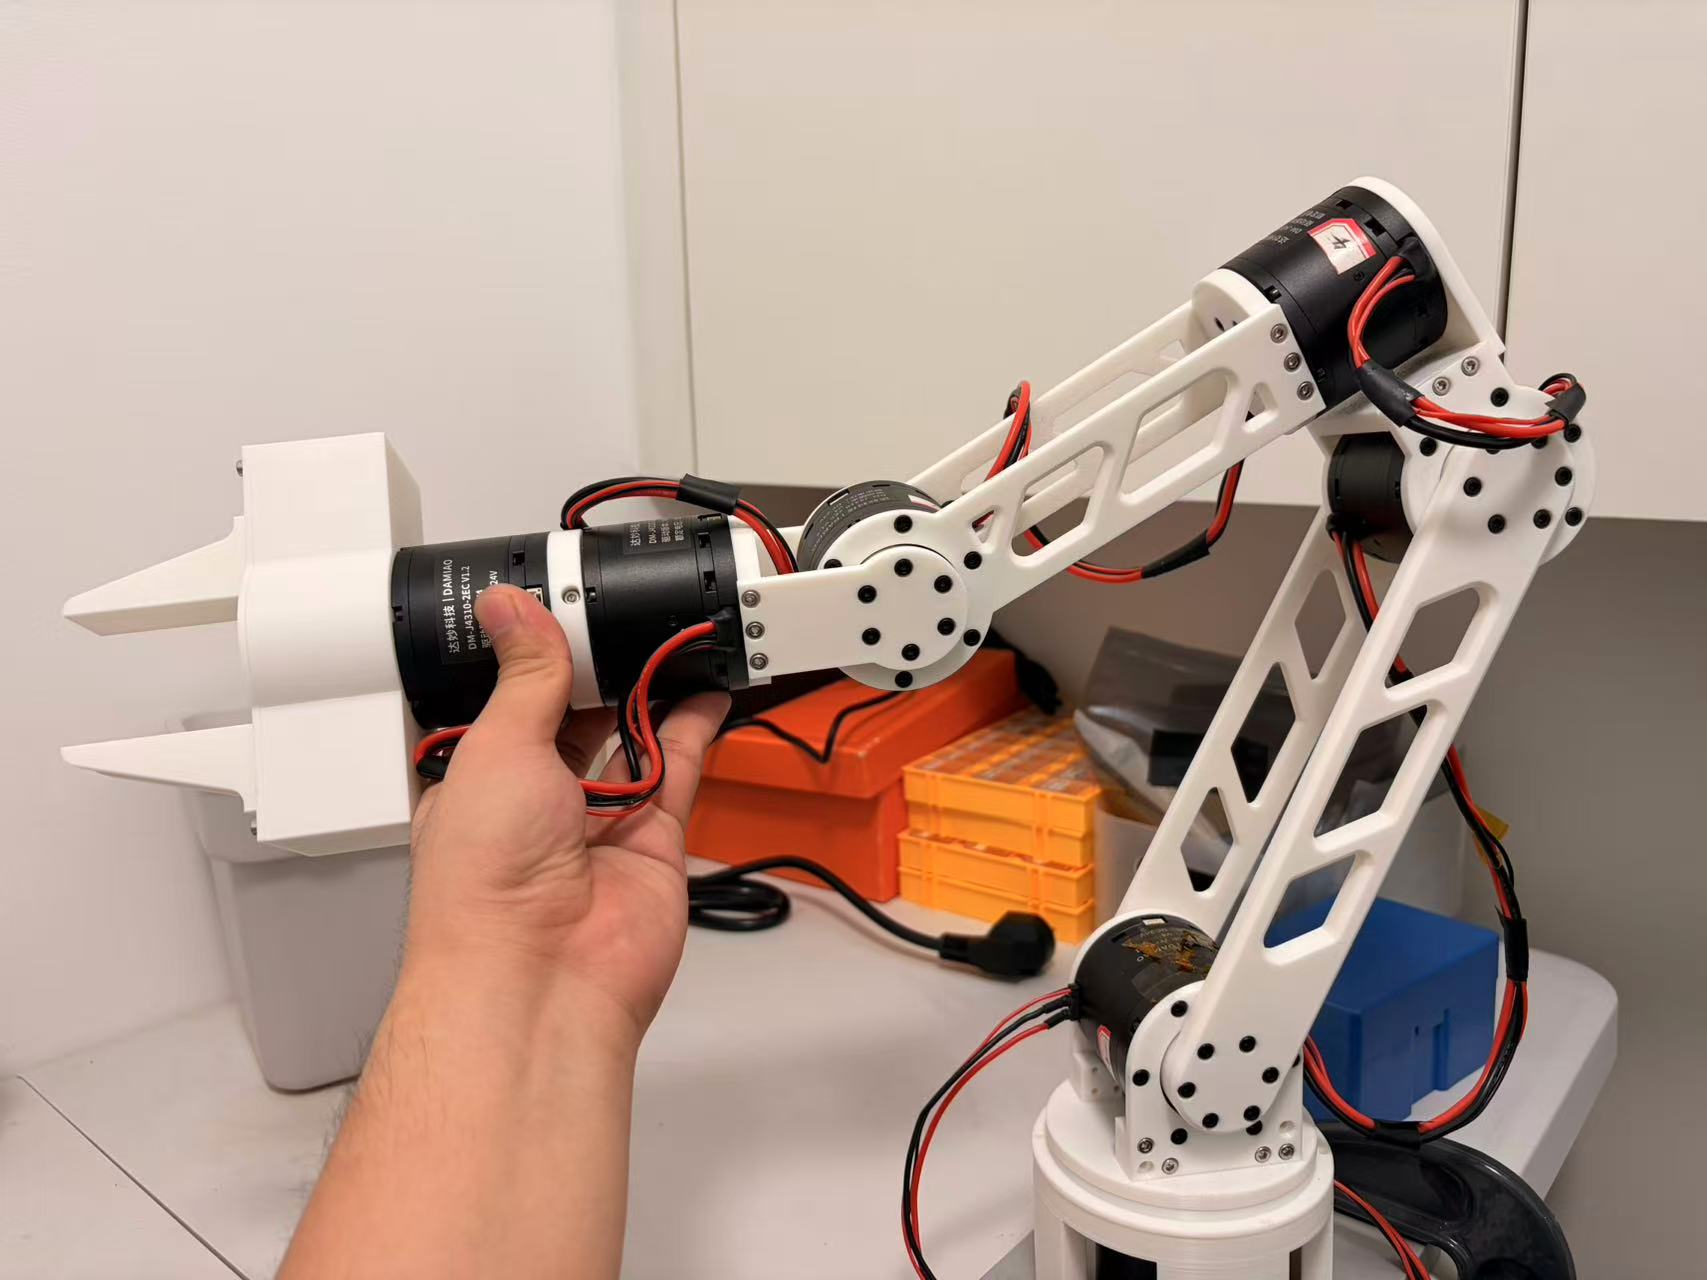
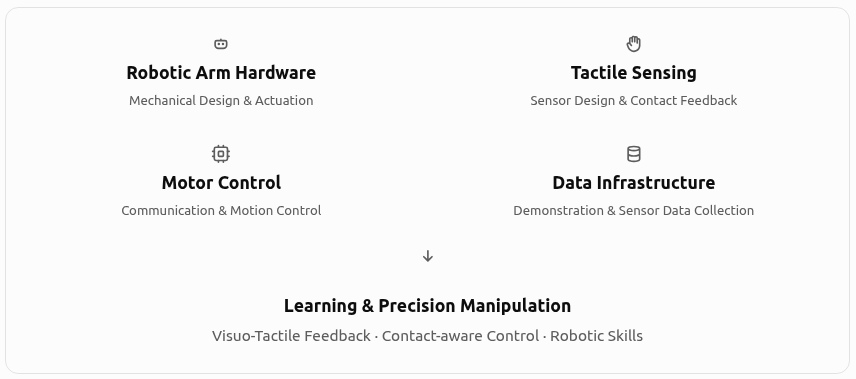
Integrating robot policy learning with in-house hardware development, including manipulation, navigation, tactile sensing, and robotic platforms for real-world embodied intelligence.

People

Team

Principal Investigator

Prof. Yan Li

Principal Investigator

Research interests: Embodied Spatial AI, Robot Learning, 3D Vision

Graduate Students

Kaiyuan Xu

Kaiyuan Xu

PhD Student

3D Vision, Foundation Models July 2026 – Present
Chengyu Lyu

Chenyu Lyu

PhD Student

Robot Policy Learning May 2026 – Present
Yuanhang Zhou

Yuanhang Zhou

MPhil Student

World Action Models Sep. 2026 – Present
Chu-An Fang

Chu-An Fang

MPhil Student

Reconstruction Sep. 2026 – Present
Jingwen Wu

Jingwen Wu

MPhil Student

Vision-Language-Navigation Oct. 2026 – Present
Zhihan Liu

Zhihan Liu

Visiting MS (TUM)

Mechanical Structure Design Sep. 2026 – Present
Zihe Jin

Zihe Jin

Visiting MS (Shanghai Tech)

Differentiable 3D Reconstruction Oct 2026 – Present
Yingzhao Li

Yingzhao Li

Co-supervised PhD Student (HIT)

SLAM, Scene Representation Jan 2025 – Present
Bingbing Hu

Bingbing Hu

Co-supervised PhD Student (XMU)

Dynamic Representation, 3D Vision June 2024 – Present
Master Student

Pengyu Huang

Master Student

Robotics, Sim-2-Real Sep 2026 – Present
Wen Zhang

Wen Zhang

Master Student

Gaussian Splatting, SLAM Sep 2026 – Present
Feiyang Lu

Feiyang Lu

Master Student

Gaussian Splatting, SLAM Sep 2026 – Present

Research Assistants & Interns

Zhicheng Lu

Zhicheng Lu

Research Assistant

World Action Models (WAM) July 2026 – Present
Ziqi Zhu

Ziqi Zhu

Research Assistant

Scene Representation Oct 2026 – Present
Yuanhao Wang

Yuanhao Wang

Intern

World Models Oct 2026 – Present
Yiming Wu

Yiming Wu

Intern

Cross-embodiment Aug 2026 – Present
Chunxuan Li

Chunxuan Li

Intern

Multi-sensor SLAM Oct 2026 – Present
Guorun Wang

Guorun Wang

X-Program UG

Robot Systems Oct 2026 – Present

Publications

Selected Publications

2026

Publication list coming soon

Add paper title, venue, authors, PDF, code, and project page links here.

FEATURED PROJECTS

Research & Engineering
Projects

Explore our ongoing work in spatial intelligence, autonomous robots, and embodied AI systems.

News

Latest Updates

EmSAIL Lab website launched.

We are recruiting PhD students, MPhil students, research assistants, and interns.

Join & Collaboration

We are recruiting motivated students and collaborators.

Students with strong backgrounds in robotics, computer vision, machine learning, spatial intelligence, or embedded systems are encouraged to apply.

Contact Us